Dashboard
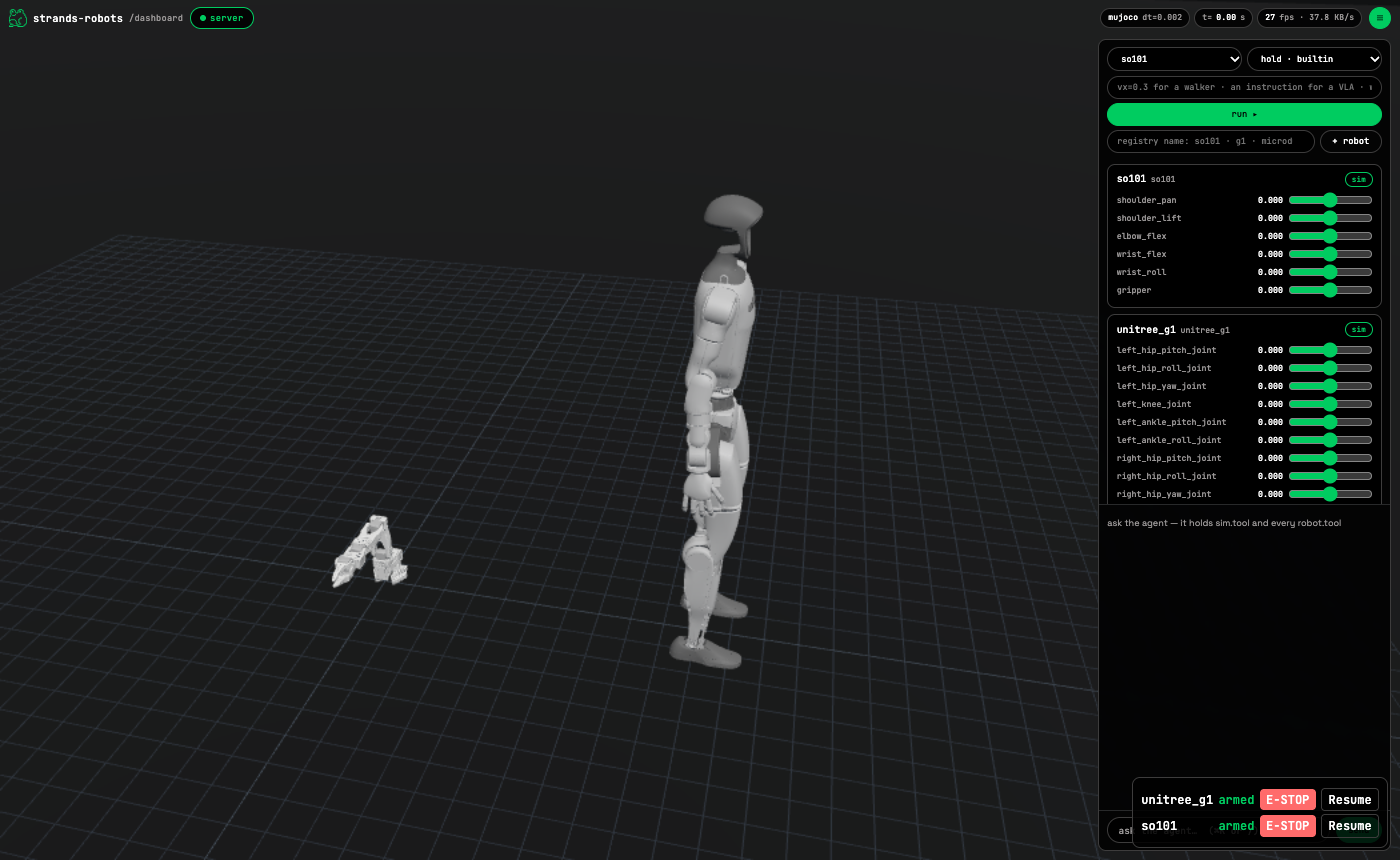
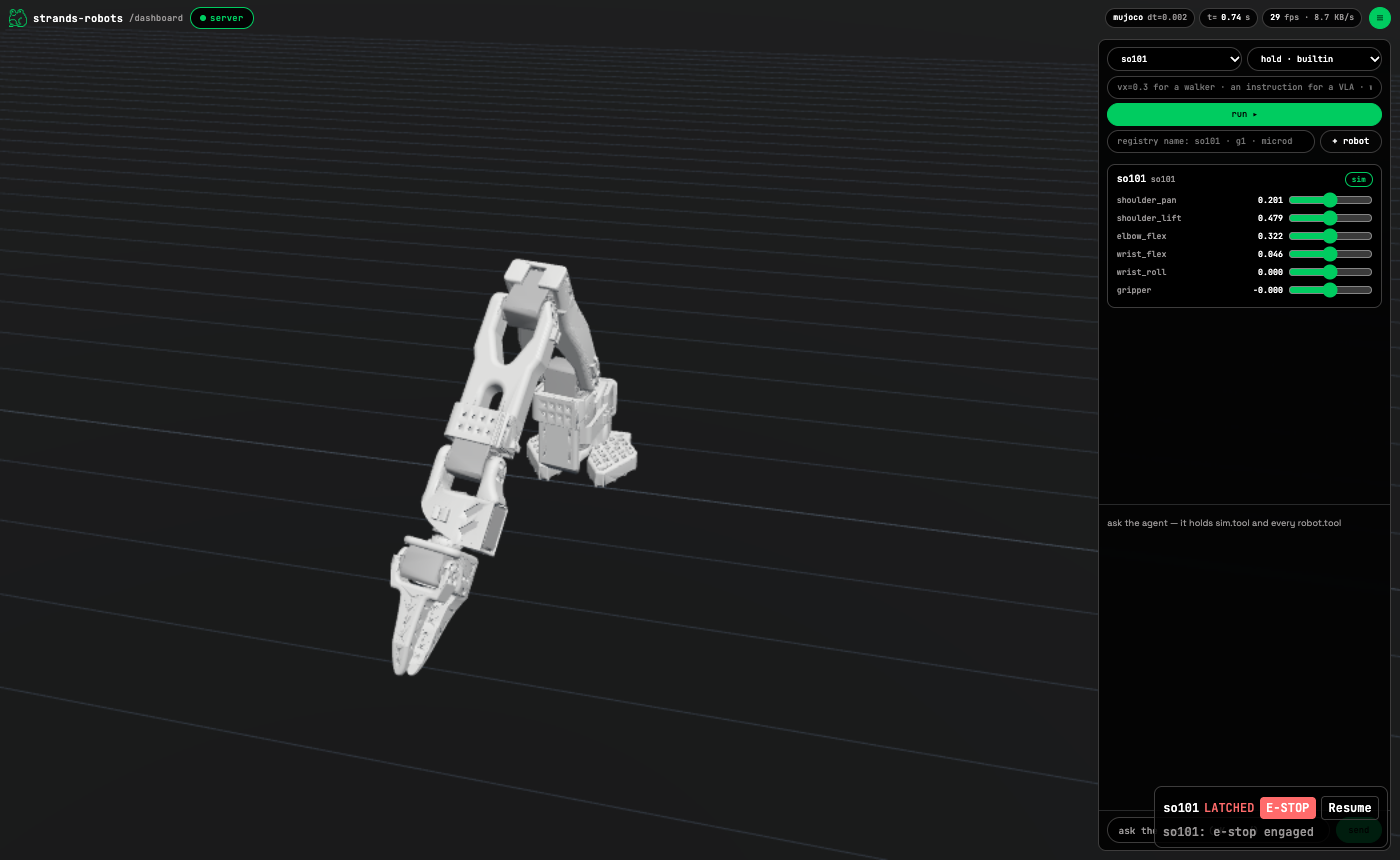
Serve a world to the browser: a live 3D view, joint controls, cameras, chat, voice and an e-stop for every robot.
The dashboard shows a world in your browser. You get a live 3D view, joint sliders, cameras, an agent chat and an e-stop for each robot.


python -m strands_robots.dashboard                       # the microduck
python -m strands_robots.dashboard so101 g1 --port 8091  # an arm and a humanoid
Open http://localhost:8090 and sign in with a passkey (see Signing in). You need the dashboard
and mujoco extras. For the chat, add the tools extra
and pass a Bedrock model id with --model.
The page's two browser engines (MuJoCo and ONNX Runtime for the web, 20 MB) are not in the package. The first page
load downloads them once, checks their hashes and keeps them in ~/.cache/strands_robots/dashboard. On a robot
network with no internet, run python -m strands_robots.dashboard --fetch on a machine that has it and copy that
folder over.
From Python
from strands_robots import Robot, Simulation
from strands_robots.dashboard import Dashboard

arm = Robot("so101")
Dashboard(Simulation.default()).serve(port=8090)
| Argument | Does |
|---|---|
robots=[real_arm] |
Adds hardware robots |
mesh=lab |
Lists every robot on a mesh |
model= |
Sets the chat model |
voice="openai" |
Turns on voice: "openai", "nova" or "auto" |
auth= |
Passkey sign-in: True (default), an Auth(ttl=..., store=...), or False (see below) |
Signing in
Every /api route and every socket needs a signed-in session. Only the page itself and the sign-in routes are open.
You sign in with a passkey: Touch ID, Windows Hello, a phone or a security key. The private key never leaves that
device. The dashboard keeps only public keys, in ~/.cache/strands_robots/dashboard-auth.json (only you can read it;
STRANDS_ROBOTS_DASHBOARD_AUTH moves it). Deleting that file signs everyone out and starts setup again.
First run. With no passkey yet, the server prints a one-time link when it starts:
Open it and press Create passkey. Without the code nobody can create the first passkey, so another program on
this machine cannot get there before you. Passkeys work on http://localhost, not on http://127.0.0.1: the page
on 127.0.0.1 sends you to localhost.
More passkeys. In the Passkeys tab you can add a passkey (for another browser or device), rename or remove
one, and sign out. Adding a passkey needs a signed-in session. The last passkey cannot be removed. A session lasts
12 hours (Auth(ttl=...) or STRANDS_ROBOTS_DASHBOARD_SESSION_TTL, in seconds). Removing a passkey ends its sessions.
A session belongs to one dashboard. A browser sends a localhost cookie to every port on the machine, including
other programs' servers, so the session cookie (strands_robots_session_<port>, HttpOnly) is only half of a session.
The other half is a proof the page keeps in that port's own storage, which the browser sends nowhere by itself; the
page adds it to every request and socket. A server on another port that is sent the cookie cannot use it, and a
session signed in on one port is refused on another. Sign in again after an upgrade from a version without this.
Scripts, notebooks and agents. Ask the dashboard for a token and send it as a bearer header:
import httpx

from strands_robots import Robot, Simulation
from strands_robots.dashboard import Dashboard

sim = Simulation()
Robot("so101", sim=sim)
dash = Dashboard(sim)
server = dash.start()
token = dash.auth.token()  # valid for the session length; keep it secret
print(httpx.get(f"{server.url}/api/scene", headers={"Authorization": f"Bearer {token}"}).status_code)  # 200
server.stop()
sim.close()
From the command line, --print-token prints one when the server starts. A token, like a passkey, is good on every
dashboard that shares the same auth file; give a dashboard its own with Auth(store=...).
Turning sign-in off. Dashboard(sim, auth=False) (or --no-auth) logs a warning and lets any local program use
every route. It is refused while a real robot is attached. You can force it with unauthenticated_hardware=True; the
page then shows that robot, but X-Confirm counts for nothing without a session, so every command to it waits for the
robot's own operator= callback (asked with a Move whose source is dashboard).
Tabs
| Tab | Does |
|---|---|
| Connect | Attaches robots from other machines over Zenoh, and adds remote LeRobot policies |
| Record | Records LeRobot v3 datasets, see Recording a dataset |
Voice
Chat and voice are off unless you turn them on. The chat panel says how.
| Flag | Turns on | Needs |
|---|---|---|
--model <id> |
the chat agent (model= to Dashboard) |
the tools extra, AWS credentials |
--voice auto · openai · nova |
talking to the page (voice= to Dashboard) |
the voice extra; OPENAI_API_KEY for openai, AWS credentials for nova |
The voice agent has the same tools as the chat. "openai" uses gpt-realtime-2. "nova" uses Amazon Nova Sonic
on Bedrock.
Security
The server listens on loopback only, refuses requests from other web pages, and answers /api and the sockets
only to a signed-in session. The page runs only the server's own script files, also when a plain file server
hosts a standalone bundle (the page carries the same policy itself). ?scene= and ?standalone= must name a file on
the page's own address, and text from the address or a scene file is shown as text. A command to a real robot also
needs the operator's X-Confirm header, which the page sends after asking. Voice never sends that header, so voice
cannot move a real robot.
X-Confirm is the operator's yes only on a signed-in request. Starting a run checks it before the policy is built, so
an unconfirmed run on a real robot dials no endpoint. Connecting a policy (POST /api/connect/policy) needs it, and so
does every POST /api/world verb except the reads (describe, pose, contacts, render). World calls run like an
agent's, so a run there cannot name a policy at a network address. add_object(path=...) loads a file only from the
folder given as Dashboard(sim, object_dir=...) or $STRANDS_ROBOTS_DASHBOARD_OBJECTS; with neither set, the
dashboard loads no object files (shapes still work):
dash = Dashboard(sim, object_dir="~/scenes/objects")
headers = {"Authorization": f"Bearer {dash.auth.token()}", "X-Confirm": "yes"}
httpx.post(f"{url}/api/world", headers=headers,
           json={"rpc": "add_object", "add_object": {"name": "mug", "path": "~/scenes/objects/mug.xml"}})
Live view in these docs
Serve these docs locally and the home page shows a dashboard running on port 8090 or 8091.
Add ?live=http://127.0.0.1:<port>/ to the home page URL to use another port. The docs page is another site, so the
session does not reach the embedded dashboard: start that simulated dashboard with --no-auth.