Quickstart
Walk a simulated robot, put two robots in one world, record a dataset, and give a robot to an agent.
Robot descriptionsFirst install the library. See Installation for details.
Walk a robot
from strands_robots import Policy, Robot

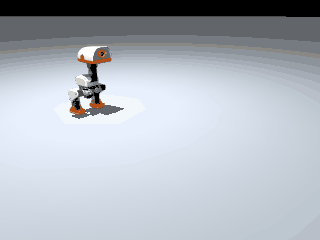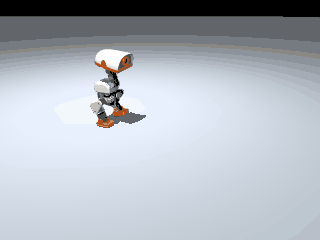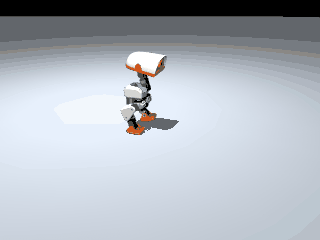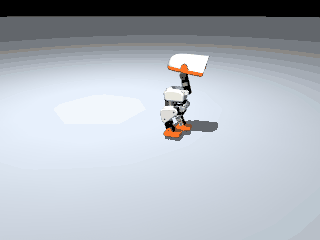
duck = Robot("microduck")
walk = Policy("microduck?vx=0.3")
duck.run(walk, seconds=10)
print(duck.pose.position)  # about 1.3 m forward
This loads the microduck and an ONNX walking policy from the Hugging Face Hub. vx=0.3 asks for 0.3 m/s forward.
Use wz=1.0 to turn, or pick another skill:
Put two robots in one world
arm, g1 = Robot("so101"), Robot("g1", position=[1, 0, 0])
arm.sim.run({arm: lambda obs: {"shoulder_pan": 0.4}, g1: Policy("holosoma")}, seconds=5)
Both robots share one physics engine and one clock. A policy can be a model or a plain function.
Record a dataset
arm.sim.camera("front", size=(320, 240), attach=arm)
arm.run(lambda obs: {"elbow_flex": 0.4}, seconds=3, record="datasets/so101-wave")
This writes a LeRobot v3 dataset. Each run adds one episode. See Recording a dataset.
Give a robot to an agent
from strands import Agent

Agent(tools=[arm.tool, arm.sim.tool])("look at the arm, then open its gripper")
The default model runs on Amazon Bedrock, so you need AWS credentials. See Agent tools.
Open the dashboard
from strands_robots.dashboard import Dashboard

Dashboard(arm.sim).serve(port=8090)  # http://localhost:8090
See Dashboard.
Edit page